AI
 AI
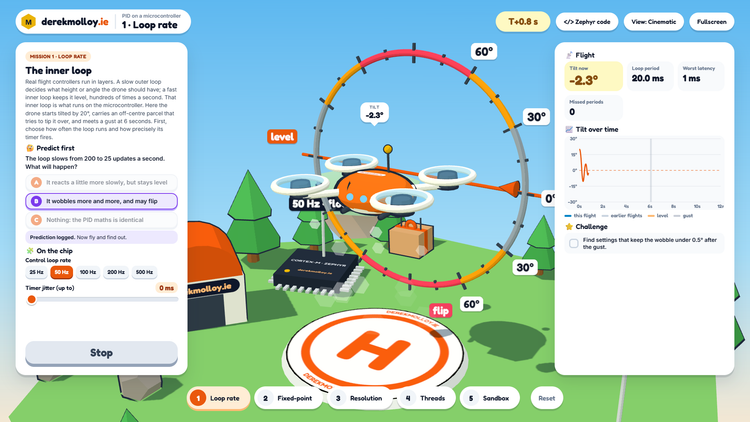
PID on a Microcontroller: Making Timing Visible in a 3D Game
A follow-on to PID Flight School. The drone's roll loop runs on a simulated Cortex-M under Zephyr, so students can see what loop rate, fixed-point maths, sensor resolution and thread priorities do to a controller.
 Derek Molloy
·
Oct 27, 2026
·
2 min read
 AI
Giving Claude Code a Logic Analyser: A Minimal Bench Harness for Zephyr on the nRF52840
An AI coding agent can write, build and flash firmware, but it cannot see the LED. This article builds a small Claude Code harness for Zephyr on the nRF52840 DK that closes the loop with real measurements from an Analog Discovery, and shows what it caught that reading the code never would.
Derek Molloy
·
Oct 26, 2026
·
45 min read
 AI
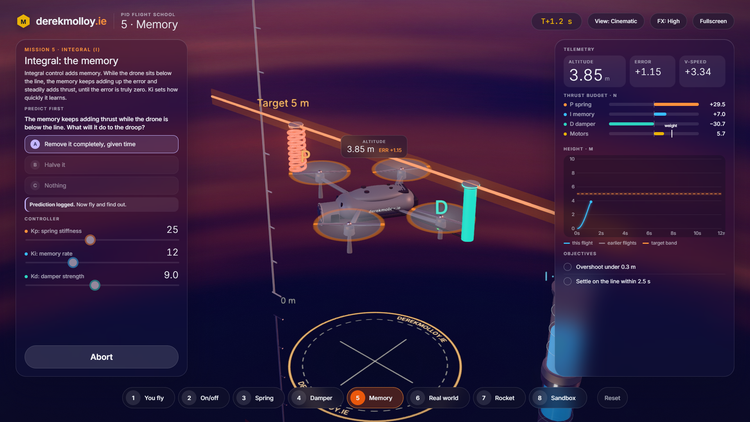
PID Flight School, Studio Edition: One Lesson, Two Looks
The second visual style of my PID Flight School game. Once the lesson is fixed in code, changing how it looks is cheap, but a more ambitious look has costs that you need to test for.
Derek Molloy
·
Oct 25, 2026
·
2 min read
 AI
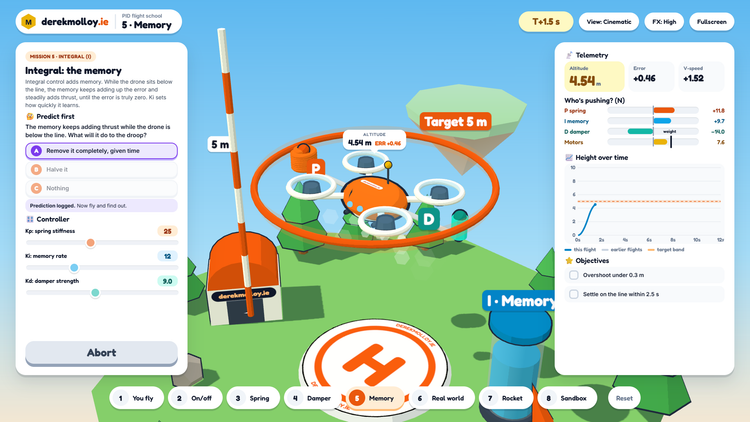
PID Flight School: Teaching a Control Loop as a 3D Game
I turned the PID demonstration from my Connected Embedded book into an eight-mission 3D game with Claude Code. This short post is about what that means for teaching.
Derek Molloy
·
Oct 25, 2026
·
3 min read
 OpenMV
The OpenMV AE3: A Time-of-Flight Doorman for the NPU
Part two of the OpenMV series shrinks the board and the power to a quarter of a watt, while running YOLO. Built on Alif's Ensemble E3 with two Cortex-M55s and two Ethos-U55 NPUs, the AE3 also carries something its bigger sibling does not, a VL53L8CX 8x8 ToF depth sensor.
Derek Molloy
·
Jul 26, 2026
·
42 min read
 OpenMV
The OpenMV N6: A MicroPython Camera with a Real NPU
The OpenMV N6 pairs an 800 MHz Cortex-M55 with ST's 600-GOPS Neural-ART NPU and a removable global-shutter camera, and MicroPython - YOLO object detection at 30 fps, in Python, under a watt. We tour the hardware properly, walk through setup, and build a people-counting application on the NPU.
Derek Molloy
·
Jul 24, 2026
·
25 min read